Byungchul Kim

Byungchul Kim
Assistant Professor
Department of Biomedical Engineering, Sungkyunkwan University
Emailbc.kim at skku.edu

Research Interests

AI-Driven Robot CodesignPhysical AISoft RoboticsUnderactuated Tendon-Driven Mechanisms

Experience

  • Assistant Professor, Biomedical Engineering, Sungkyunkwan University (2026.3 – Present)
  • Postdoctoral Research Associate, MIT CSAIL (2023.1 – 2026.2)
  • Research Associate, Harvard Microrobotics Lab (2023.3 – 2025.9)
  • Postdoctoral Research Associate, Soft Robotics Research Center (SRRC), Seoul National University (2020.8 – 2022.12)

Education

  • Ph.D. Mechanical Engineering, Seoul National University (2014.9 – 2020.8)
  • M.S. Mechanical Engineering, Seoul National University (2012.3 – 2014.2)
  • B.S. Mechanical Engineering, Seoul National University (2008.3 – 2012.2)

Bio

Byungchul Kim is an Assistant Professor in the Department of Biomedical Engineering at Sungkyunkwan University (SKKU), Korea. From 2023 to 2026, he was a Postdoctoral Research Associate at MIT, working with Professor Daniela Rus in the Computer Science and Artificial Intelligence Laboratory (CSAIL). Before MIT, he was a Postdoctoral Research Associate at the Soft Robotics Research Center (SRRC), collaborating with Professor Kyu-Jin Cho in the Department of Mechanical Engineering at Seoul National University.

Dr. Kim earned his B.S., M.S., and Ph.D. degrees in Mechanical and Aerospace Engineering, all from Seoul National University. His research interests include soft robotics, hand-wearable robotic systems, and underactuated tendon-driven mechanisms.

Publications 18
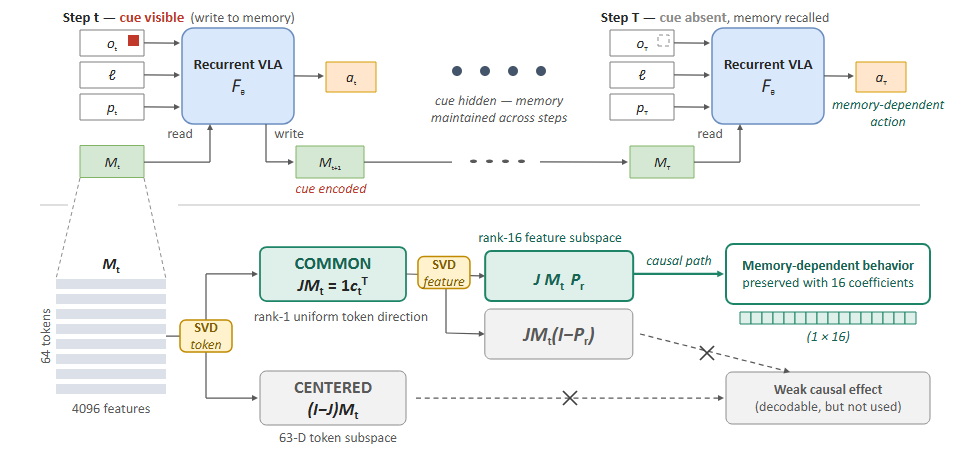
What Crosses Time? From Recurrent State to Causal Memory in Vision-Language-Action Models
Hyungjun Nam, Young Kyun Jang, Byungchul Kim
NeurIPS 2026 Workshop on Personalized, Aligned, Long-Term Memory for AI Systems (PALM) & 8th Robot Learning Workshop
Genesis: A Generative and Universal Physics Engine for Robotics and Beyond,
Zhou Xian, Yiling Qiao, […] Byungchul Kim, […] and Chuang Gan (among 51 authors)
EMBGUARD: Constructing Hazard-Aware Guardrails for Safe Planning in Embodied Agents
Dongwook Choi, Taeyoon Kwon, Bogyung Jeong, Minju Kim, Yeonjun Hwang, Hyojun Kim, Byungchul Kim, Young Kyun Jang, Jinyoung Yeo
2026 International Conference on Machine Learning (ICML)
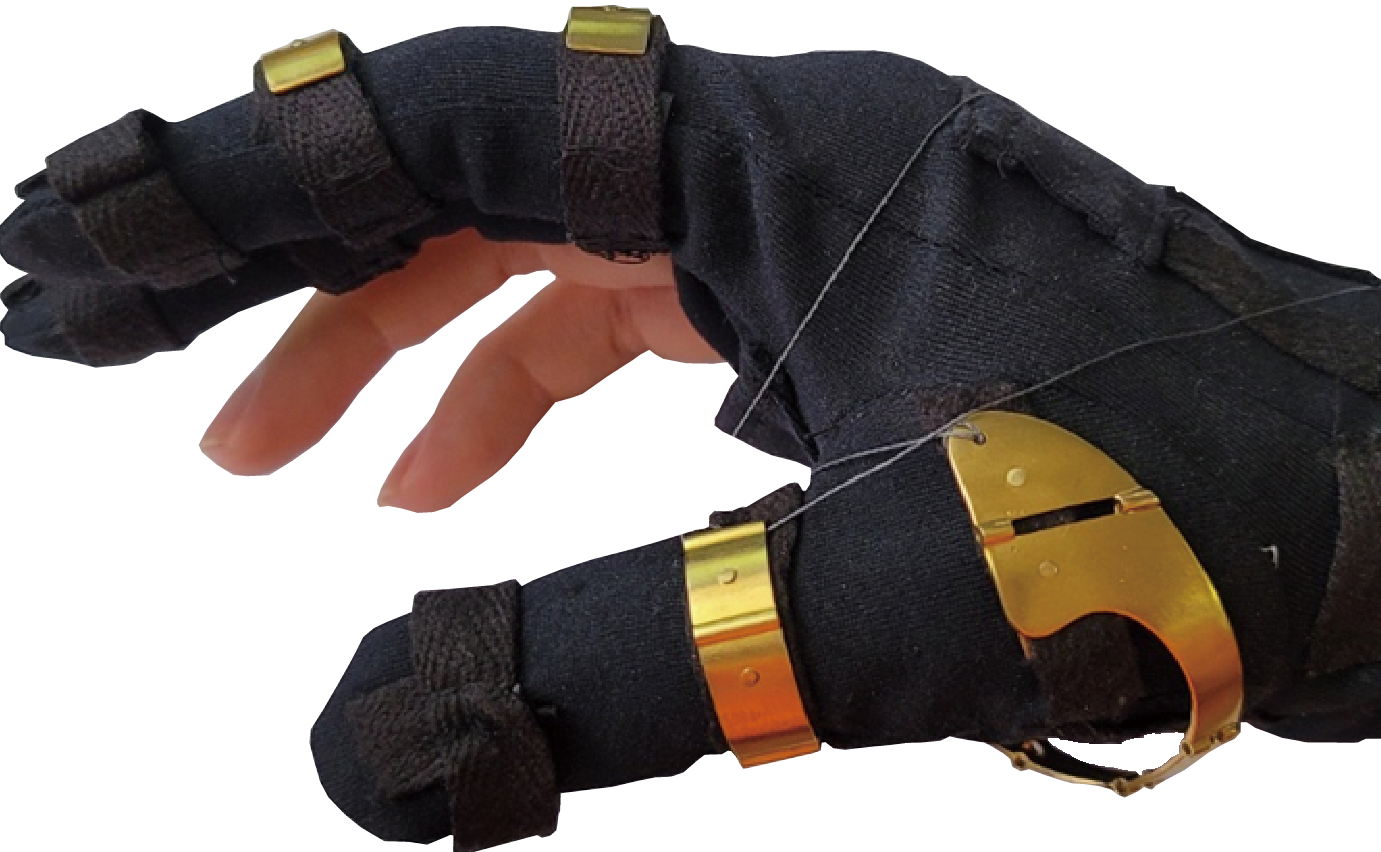
Exo-Glove Pinch: Soft Hand-wearable Robot Designed through the Analysis of the Constrained Tendon Routing
Byungchul Kim, Useok Jeong, and Kyu-Jin Cho
IEEE Robotics and Automation Letters (RA-L)
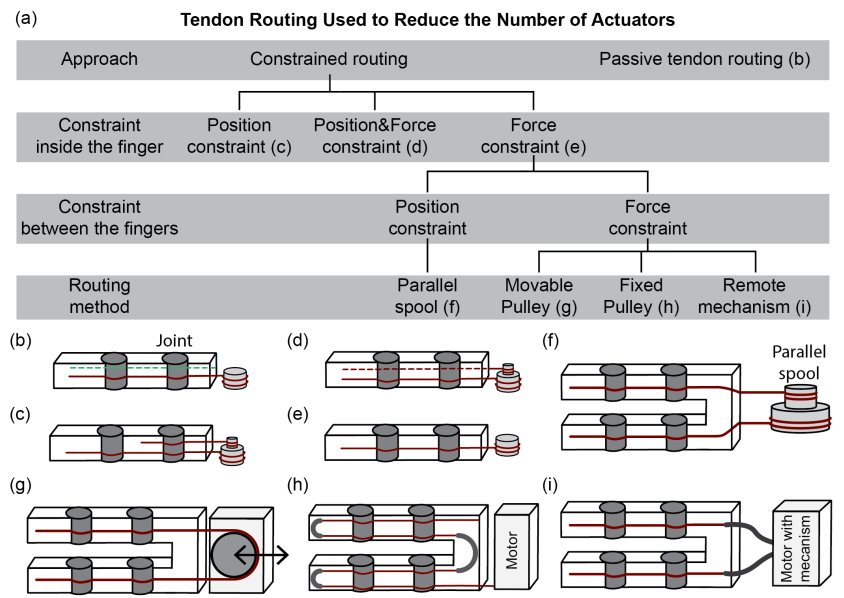
Dual-Tendon Routing: Tendon Routing for Under-actuated Tendon-Driven Soft Hand-wearable Robot
Byungchul Kim, Useok Jeong, and Kyu-Jin Cho
IEEE Robotics and Automation Letters (RA-L)
Exo-Glove Shell: A Hybrid Exo-Glove for the Thumb Opposition with an Under-Actuated Tendon-Driven System,
Byungchul Kim, Hyungmin Choi, Kyubum Kim, Sejin Jeong, and Kyu-Jin Cho
Soft Robotics
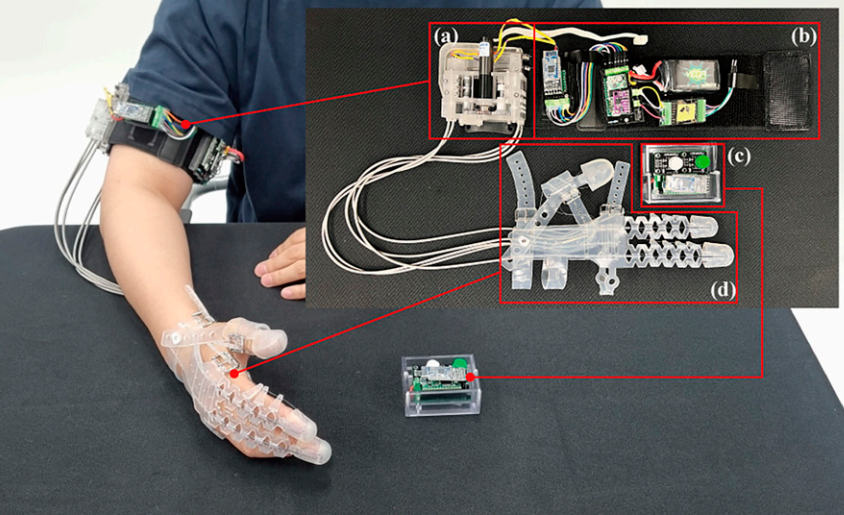
Exo-Glove Poly III: Grasp Assistance by Modulating Thumb and Finger Motion Sequence with a Single Actuator,
Kyu Bum Kim, Hyungmin Choi, Byungchul Kim, Brian Byunghyun Kang, Sangheui Cheon, and Kyu-Jin Cho
Soft Robotics
Generative-AI-Driven Jumping Robot Design Using Diffusion Models
Byungchul Kim*, Tsun-Hsuan Wang*, Daniela Rus
ICRA 2025
Position and Force Constraints in Underactuated Tendon-Driven Systems
Byungchul Kim*, Useok Jeong, Kyu-Jin Cho
ICRA 2025 Workshop on Mechanisms in Robot Manipulation
Strong Compliant Grasps Using a Cable-Driven Soft Gripper
Gregory Xie, Lillian Chin, Byungchul Kim, Rachel Holladay, and Daniela Rus
2024 IROS
Underactuated Robotic Gripper with Fiber-Optic Force Sensing Tendons
Jaehyun Lee, Byungchul Kim, Kyu-Jin Cho, and Yong-Lae Park
IEEE Robotics and Automation Letters (RA-L)
Diffusebot: Breeding soft robots with physics-augmented generative diffusion models
Tsun-Hsuan Wang, Juntian Zheng, Pingchuan Ma, Yilun Du, Byungchul Kim, Andrew Everett Spielberg, Joshua B. Tenenbaum, Chuang Gan, and Daniela Rus
Neural Information Processing Systems (NeurIPS) 2023, Oral presentation
Laser-Etching Flexible Sensors for Robotic Touch Recognition
Cedric Honnet, Yunyi Zhu, Martin Nisser, Chao Liu, Byungchul Kim, Jae Hun Seol, Jongho Lee, Daniela Rus, and Stefanie Mueller
2023 ICRA (late braking results)
Building Simple Yet Competent Soft-Rigid Hybrid Hand Wearable Robots
Byungchul Kim and Kyu-Jin Cho
2022 Bio & Bio Workshop
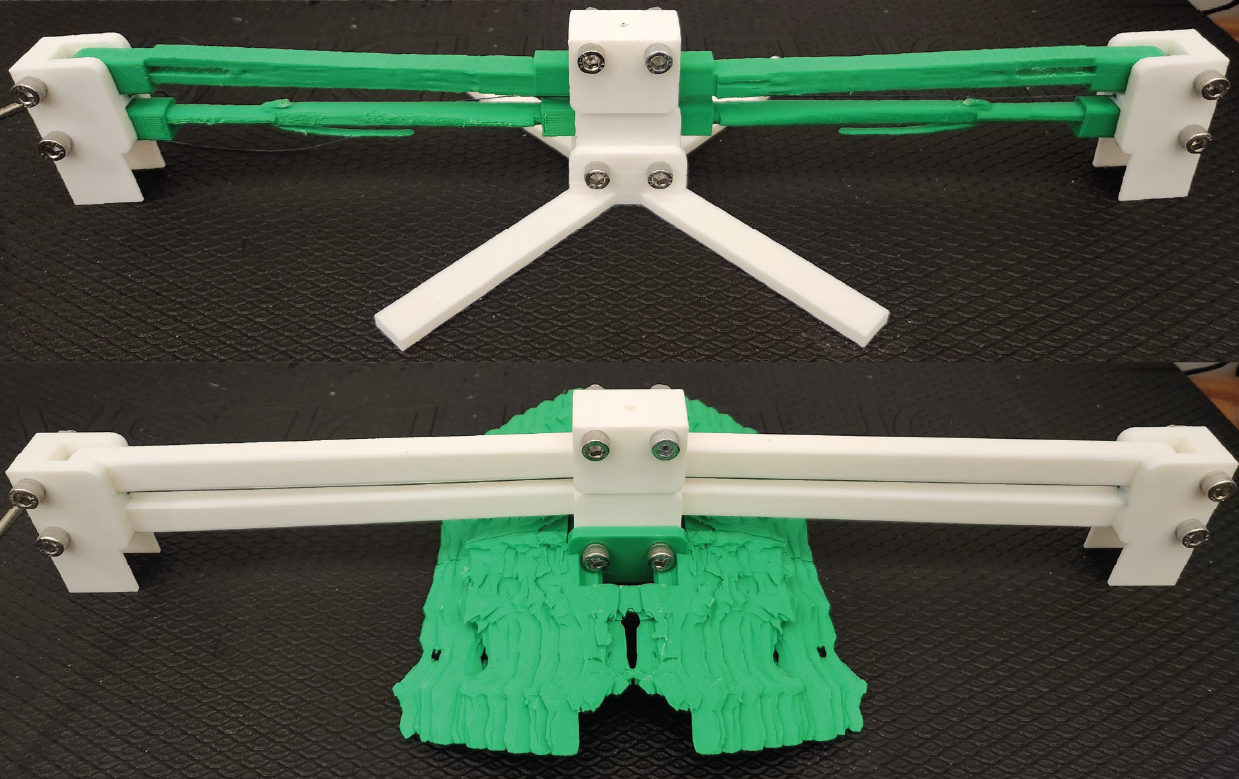
Slider-Tendon Linear Actuator with Under-actuation and Fast-connection for Soft Wearable Robots
Byungchul Kim, Useok Jeong, Brian Byunghyun Kang, and Kyu-Jin Cho
IEEE/ASME Transactions on Mechatronics
Slider-Tendon Linear Actuator with Under-actuation and Fast-connection for Soft Wearable Robots (presentation only)
Byungchul Kim, Useok Jeong, Brian Byunghyun Kang, and Kyu-Jin Cho
International Conference on Advanced Intelligent Mechatronics (presentation only)
Joint Angle Estimation of a Tendon-Driven Soft Wearable Robot through a Tension and Stroke Measurement,
Byungchul Kim, Jiwon Ryu, and Kyu-Jin Cho
Sensors
Development and assessment of a hand assist device: GRIPIT
Byungchul Kim, Hyunki In, Daeyoung Lee, Kyu-Jin Cho
Journal of NeuroEngineering and Rehabilitation